|
Won Kyung Do (도원경, 都源京) I recently graduated with a Ph.D. in Mechanical Engineering from Stanford University and now work at a stealth startup. During my Ph.D., I was advised by Prof. Monroe Kennedy III in the ARM Lab. Before coming to Stanford, I received B.S. in Mechanical Engineering from Seoul National University, advised by Prof. Dongjun Lee. I was fortunate to work as a research intern at Naver Labs in 2018. |
|
ResearchI'm interested in tactile sensing, dexterous manipulation, small object handling, control theory, optimization, and human-robot interaction. I believe improving dexterity of the robots is essential for enabling them to perform precise tasks such as manipulating small objects autonomously. Representative papers are highlighted. |
|
TensorTouch: Calibration of Tactile Sensors for High Resolution Stress Tensor and Deformation for Dexterous Manipulation
Won Kyung Do, Matthew Strong, Aiden Swann, Boshu Lei, Monroe Kennedy III IEEE Transactions on Robotics (T-RO), 2026 To be presented at ICRA 2027 project page / DOI / arXiv Combines finite element analysis and deep learning to estimate dense stress tensors, deformation, and contact forces from optical tactile images, enabling dexterous manipulation of deformable objects. |
|
|
DOT-Sim: Differentiable Optical Tactile Simulation with Precise Real-to-Sim Physical Calibration
Yang You, Won Kyung Do, Aiden Swann, Rika Antonova, Monroe Kennedy, Leonidas Guibas ICRA, 2026 arXiv Uses differentiable material point simulation and calibrated optical rendering to model large tactile-sensor deformations and transfer simulation-trained perception and manipulation to real sensors. |
|
|
|
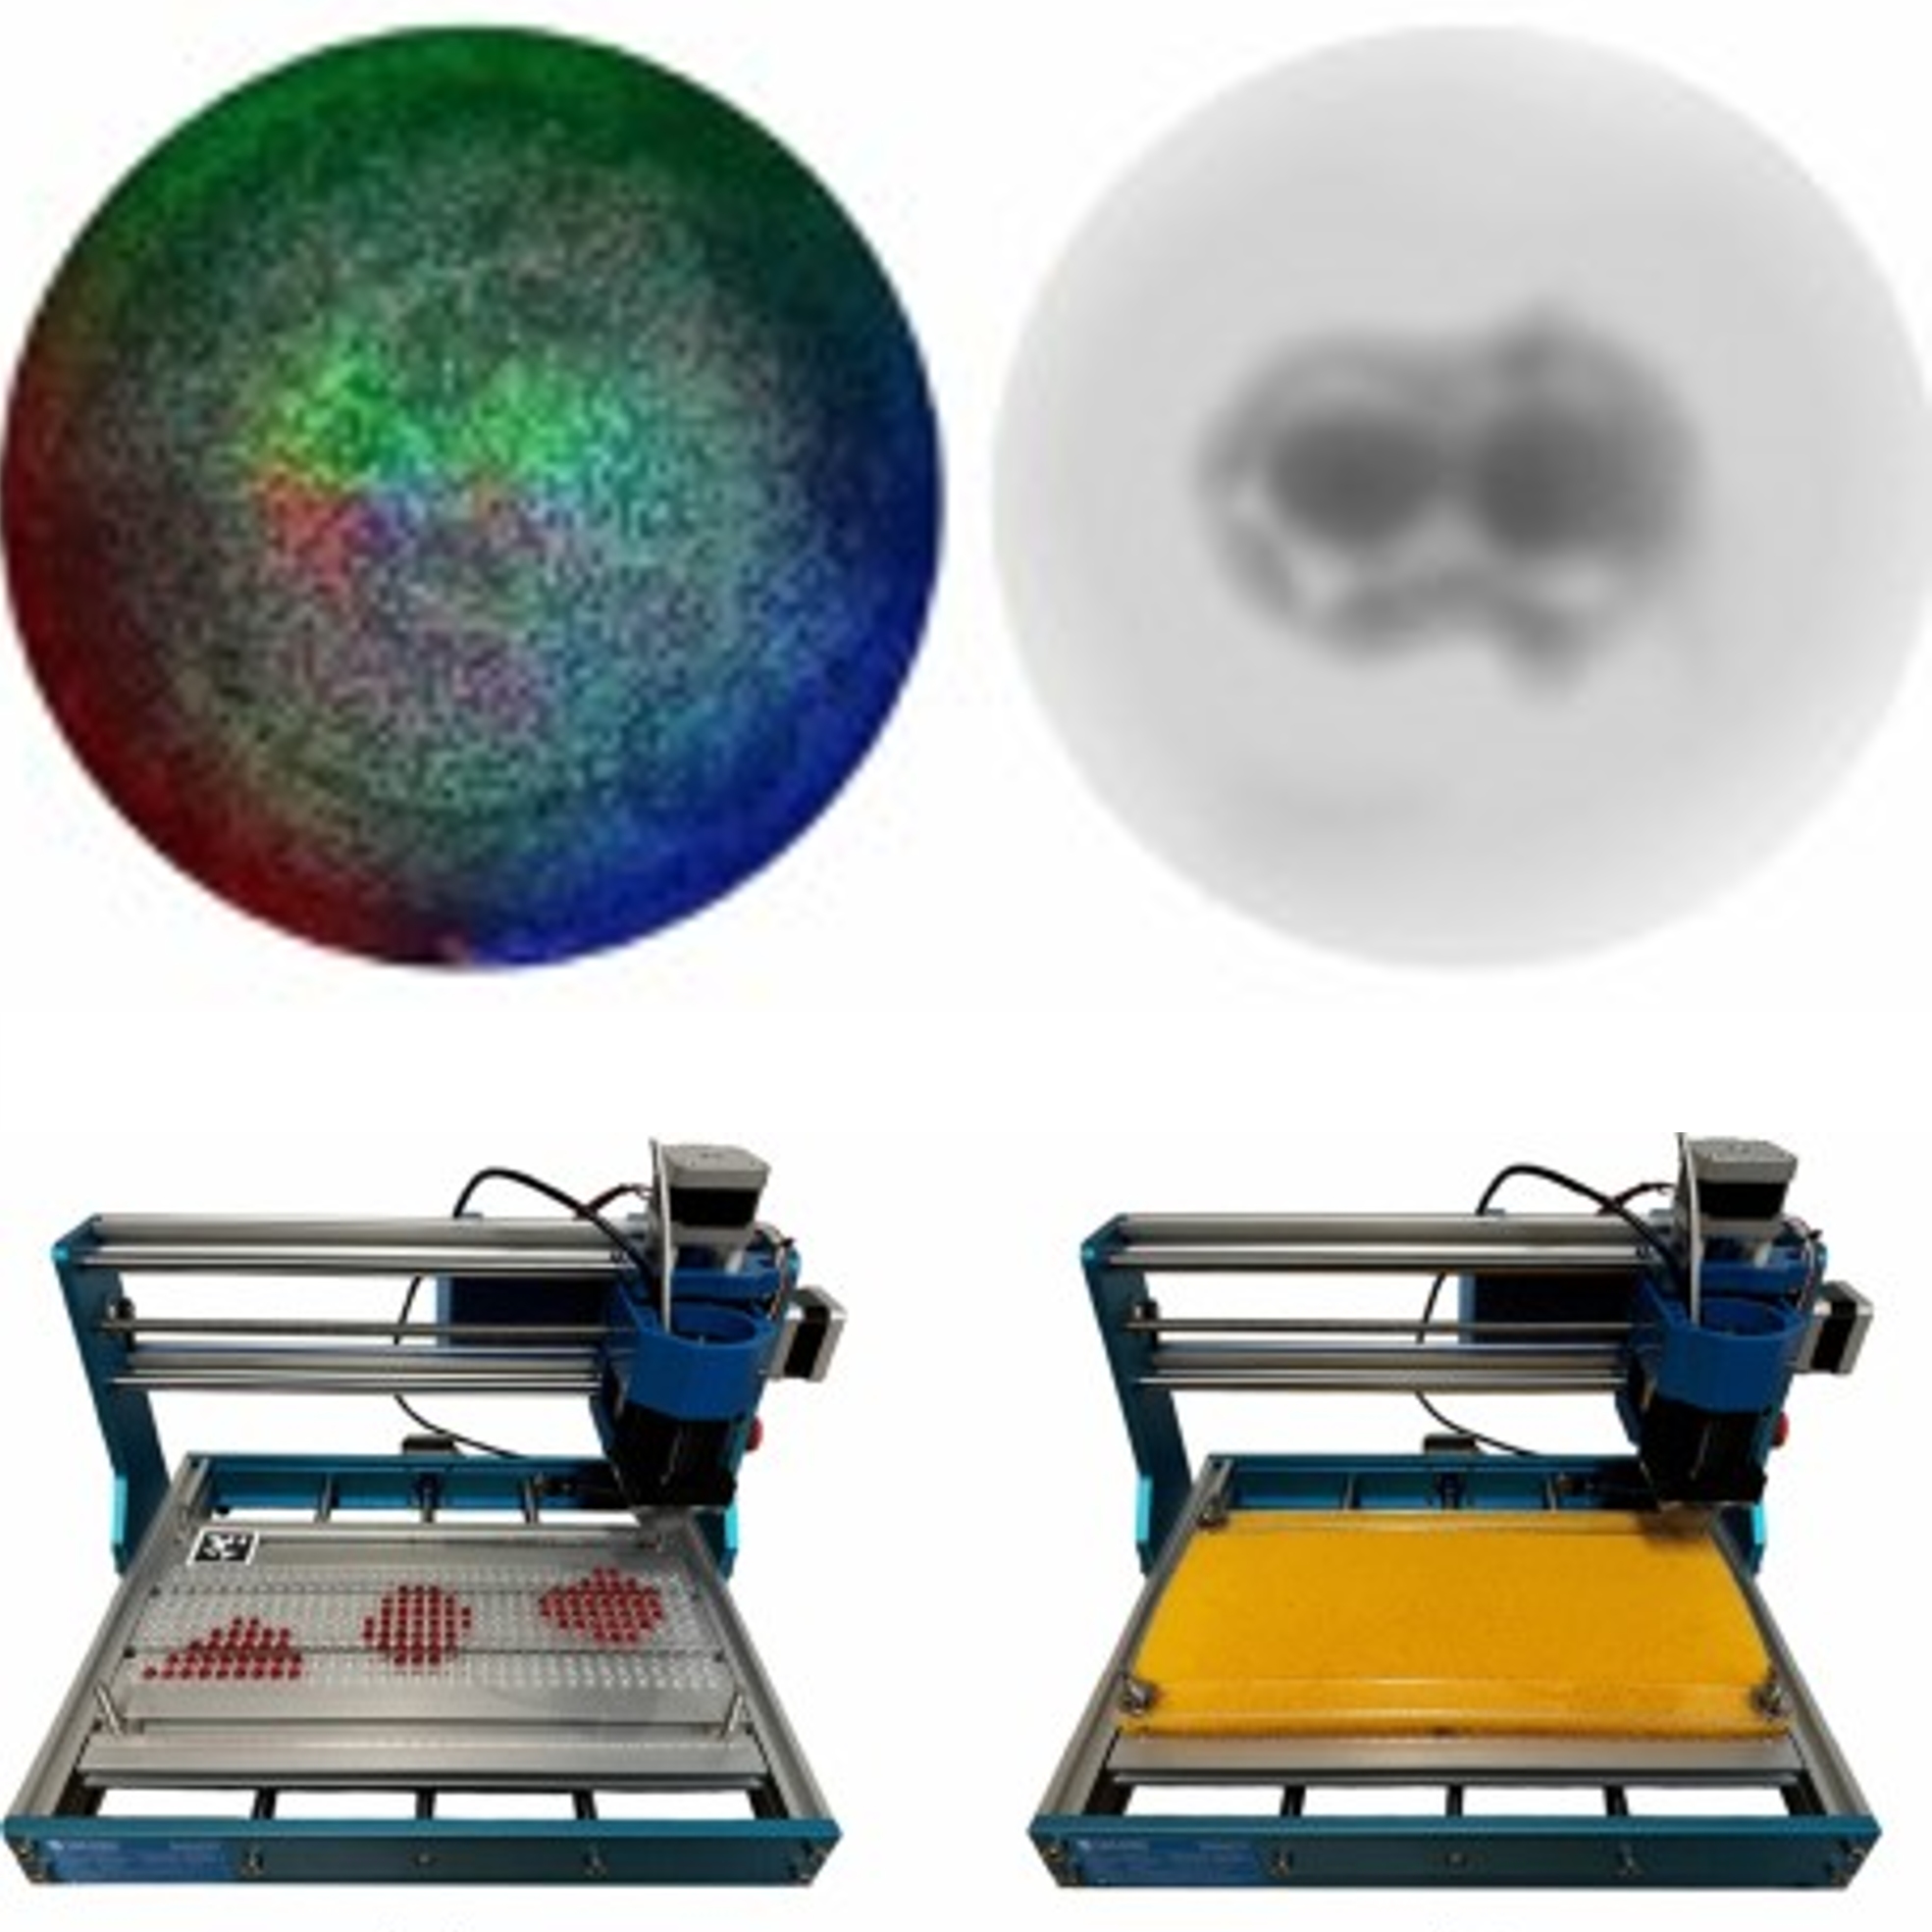
DenseTact-Mini: An Optical Tactile Sensor for Grasping Multi-Scale Objects From Flat Surfaces
Won Kyung Do, Ankush Dhawan, Mathilda Kitzmann, Monroe Kennedy III ICRA, 2024 (Best Paper Award Finalist in Robot Manipulation) project page / arXiv / video / github Developed a novel optical tactile sensor that can grasp multi-scale objects from flat surfaces (from 1mm basil seeds and small paperclips to items nearly 15mm). |
|
Embedded object detection and mapping in soft materials using optical tactile sensing
Jose A. Solano-Castellanos Won Kyung Do, Monroe Kennedy III SN Computer Science 5 (4), 1-11, 2024 project page / video / DOI Describes a method that uses optical tactile sensing for efficient detection and mapping of objects embedded in soft materials, demonstrated with quartz beads beneath polyethylene foam. |
|
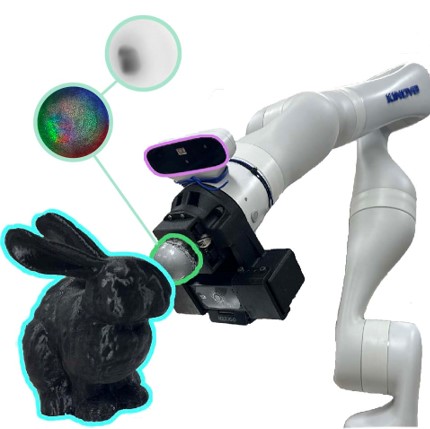
Touch-GS: Visual-Tactile Supervised 3D Gaussian Splatting
Aiden Swann*, Matthew Strong*, Won Kyung Do, Gadiel Sznaier Camps, Mac Schwager, Monroe Kennedy III IROS, 2024 project page / arXiv / Video / Github Presents a novel method that enhances 3D Gaussian Splatting with optical tactile sensors for more accurate object representation in robotics, integrating tactile data with monocular depth images and a new variance-weighted loss function for improved scene synthesis across various materials. |
|
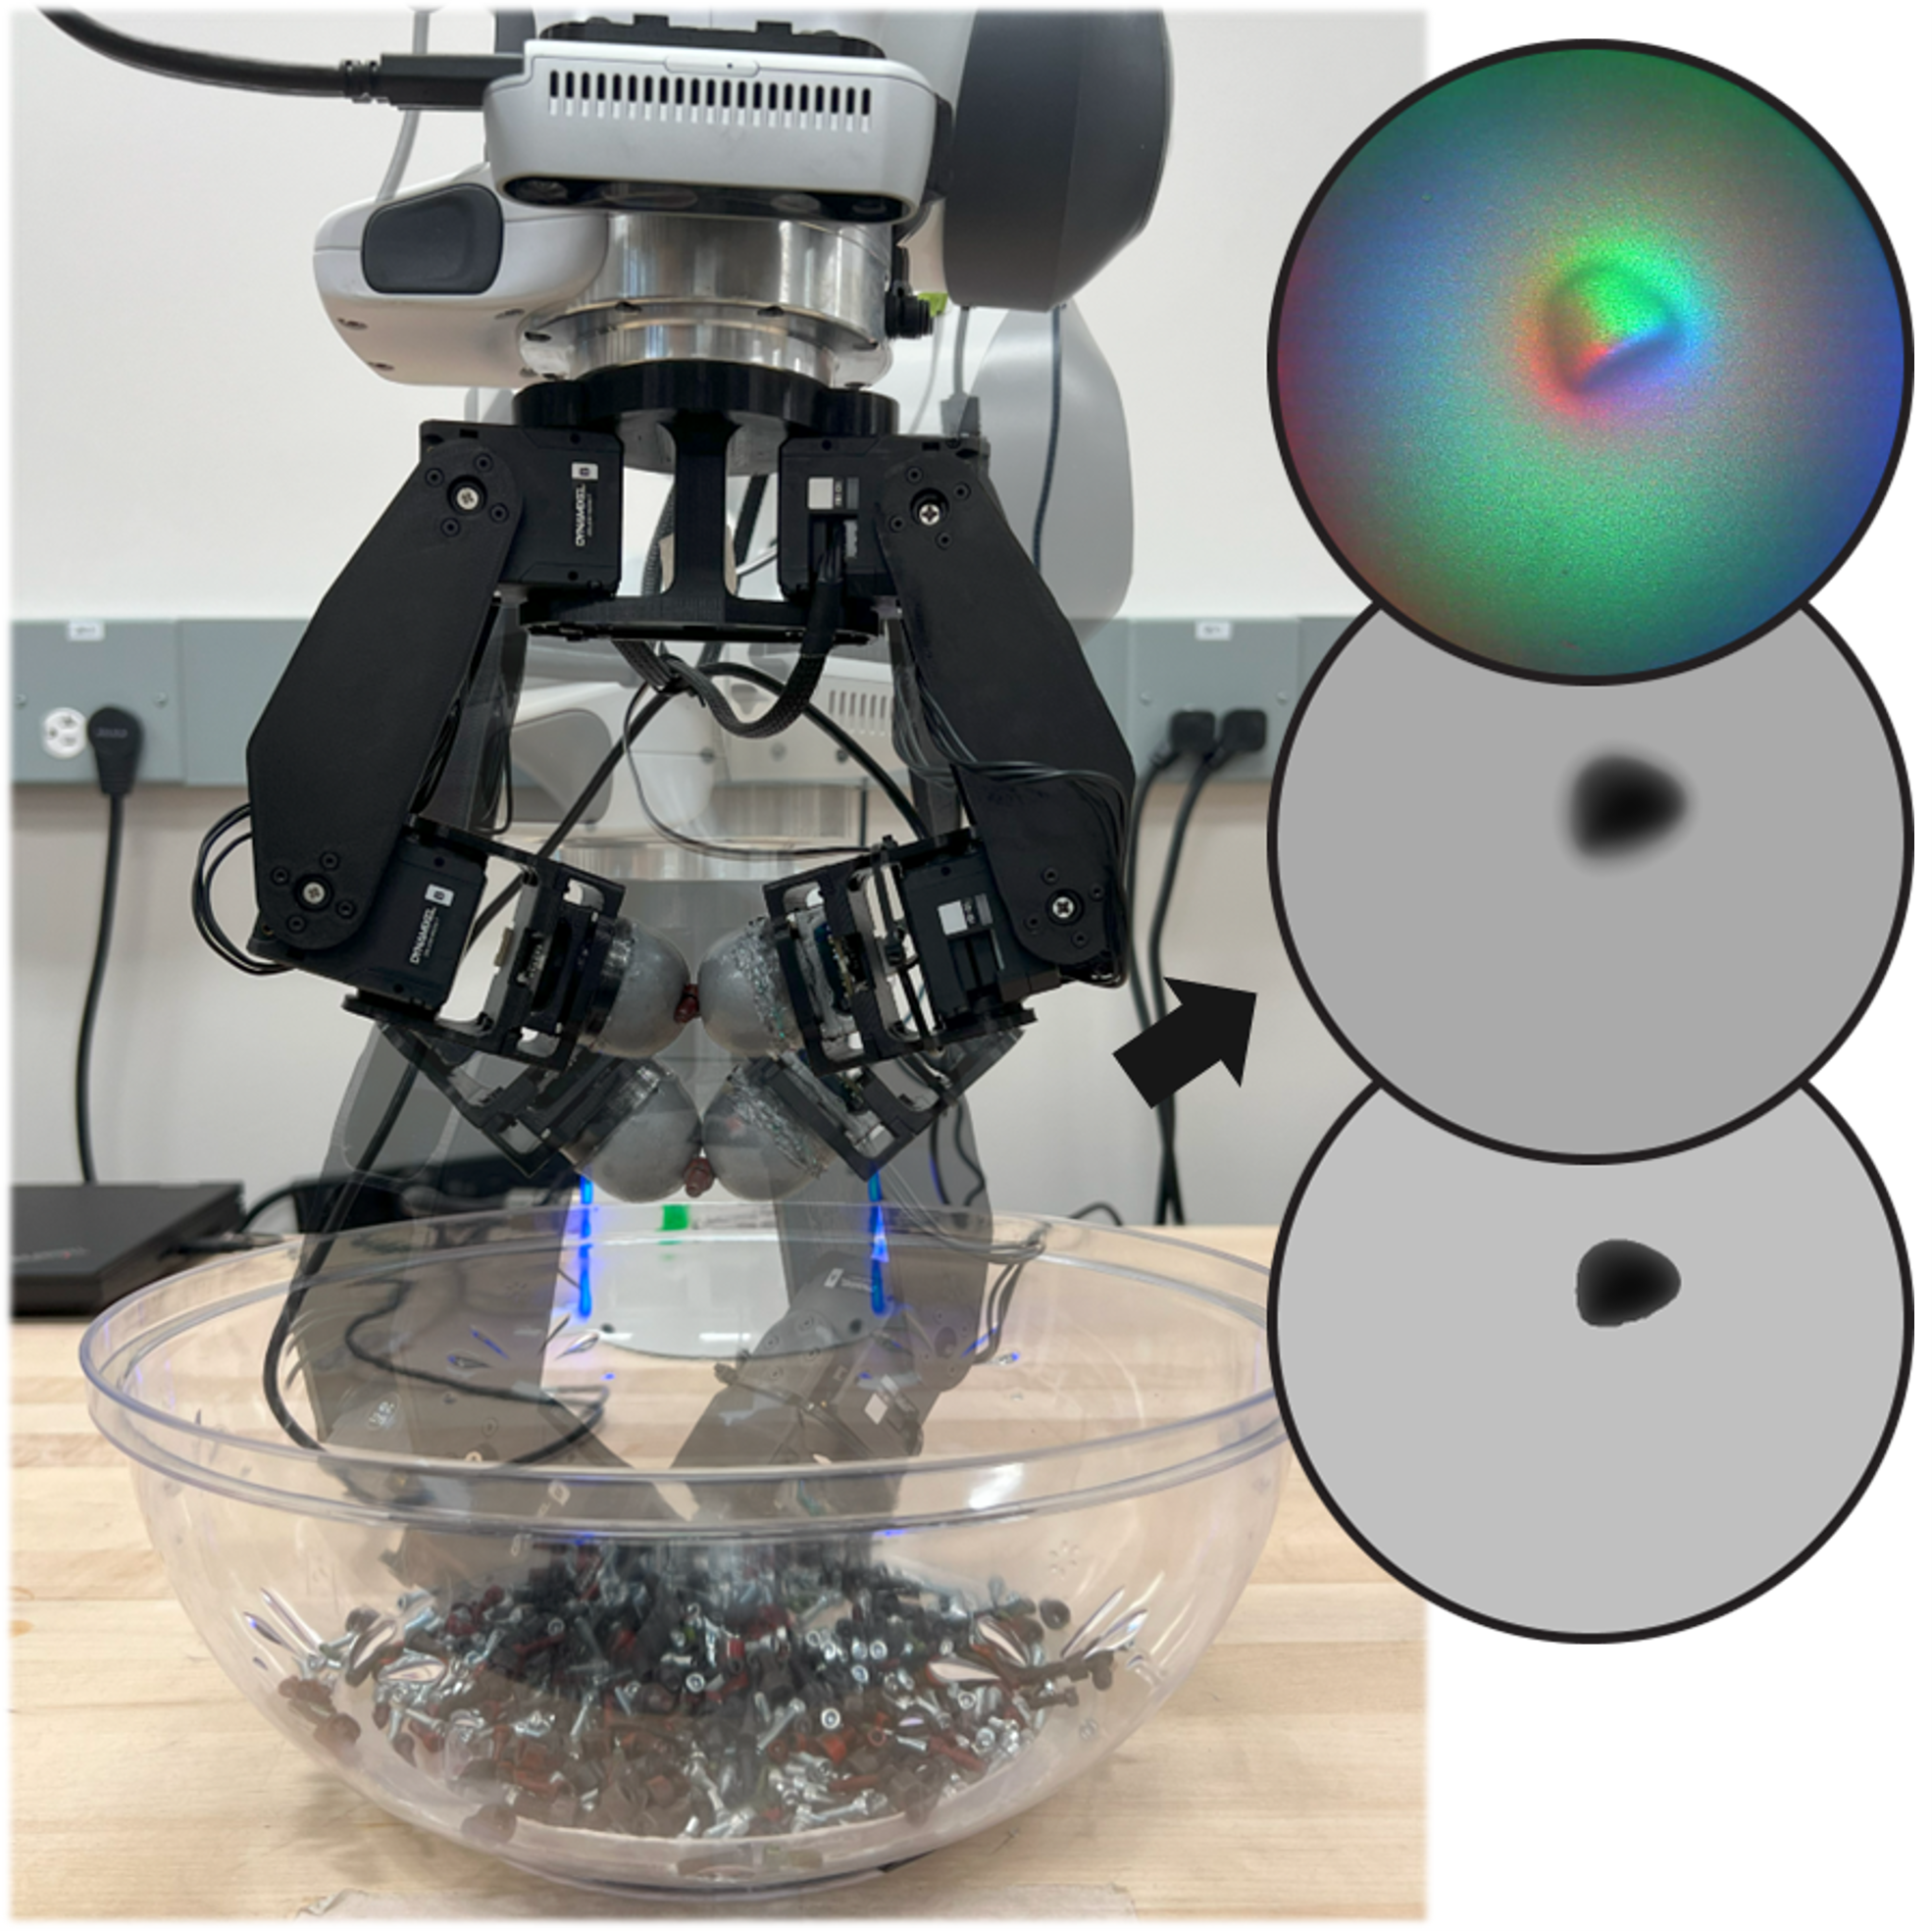
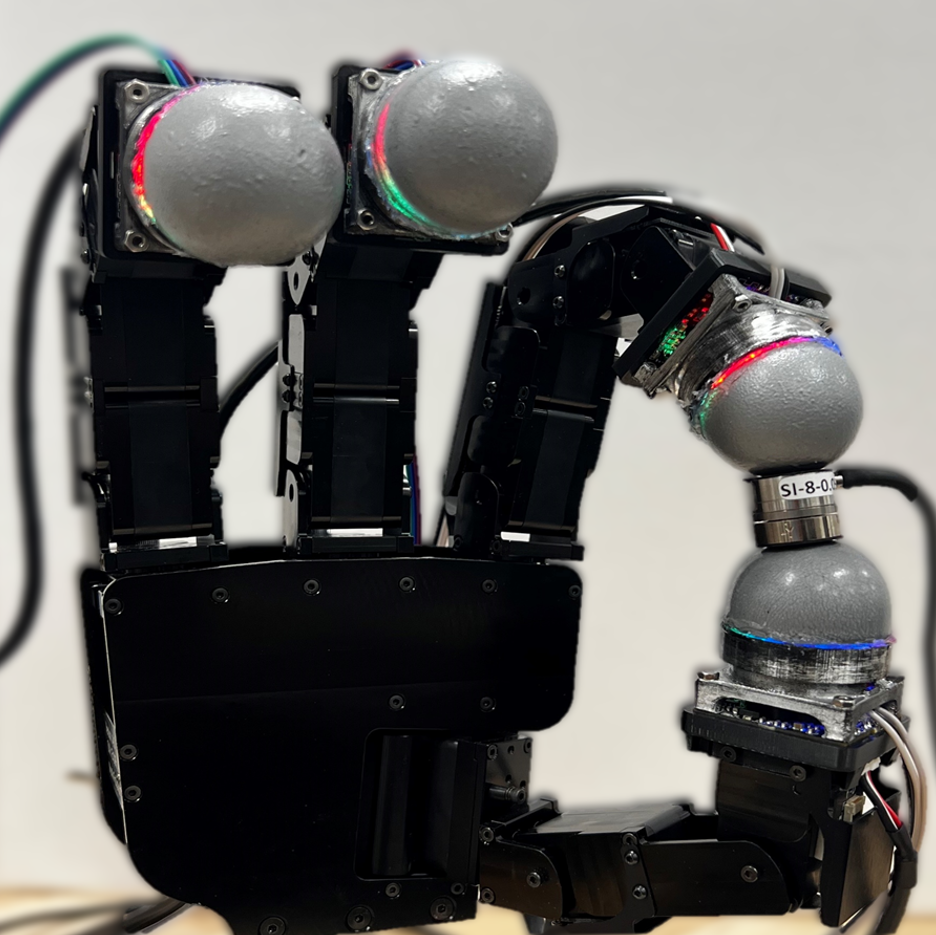
Inter-finger Small Object Manipulation with DenseTact Optical Tactile Sensor
Won Kyung Do, Bianca Aumann, Camille Chungyoun, Monroe Kennedy III RA-L, 2023 project page / DOI / Video / Github Introduces a tactile sensor-equipped gripper with DenseTact 2.0, enhancing precision and success in grasping small objects in cluttered environments, integrated with a specialized control algorithm and dataset for effective object classification and manipulation. |
|
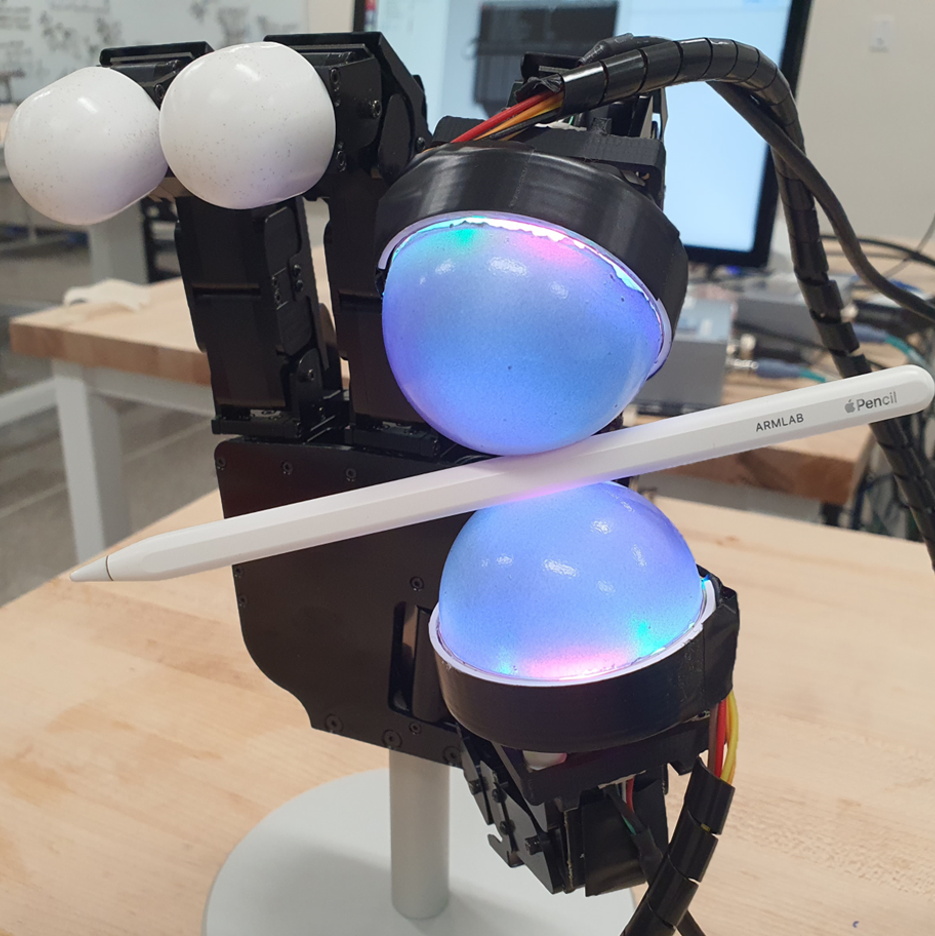
DenseTact 2.0: Optical tactile sensor for shape and force reconstruction
Won Kyung Do, Bianca Aumann, Monroe Kennedy III ICRA, 2023 DOI / Video Designed DenseTact 2.0, an advanced optical-tactile sensor that accurately reconstructs shapes and measures forces in robotic fingertips with smaller form factors and higher resolution than previous models. |
|
Densetact: Optical tactile sensor for dense shape reconstruction
Won Kyung Do, Monroe Kennedy III ICRA, 2022 DOI / Video / Featured in : Stanford Engineering Introduces Densetact, a cost-effective, high-resolution tactile sensor that uses a fisheye camera and deep neural networks for precise 3D surface modeling in real-time. |
|
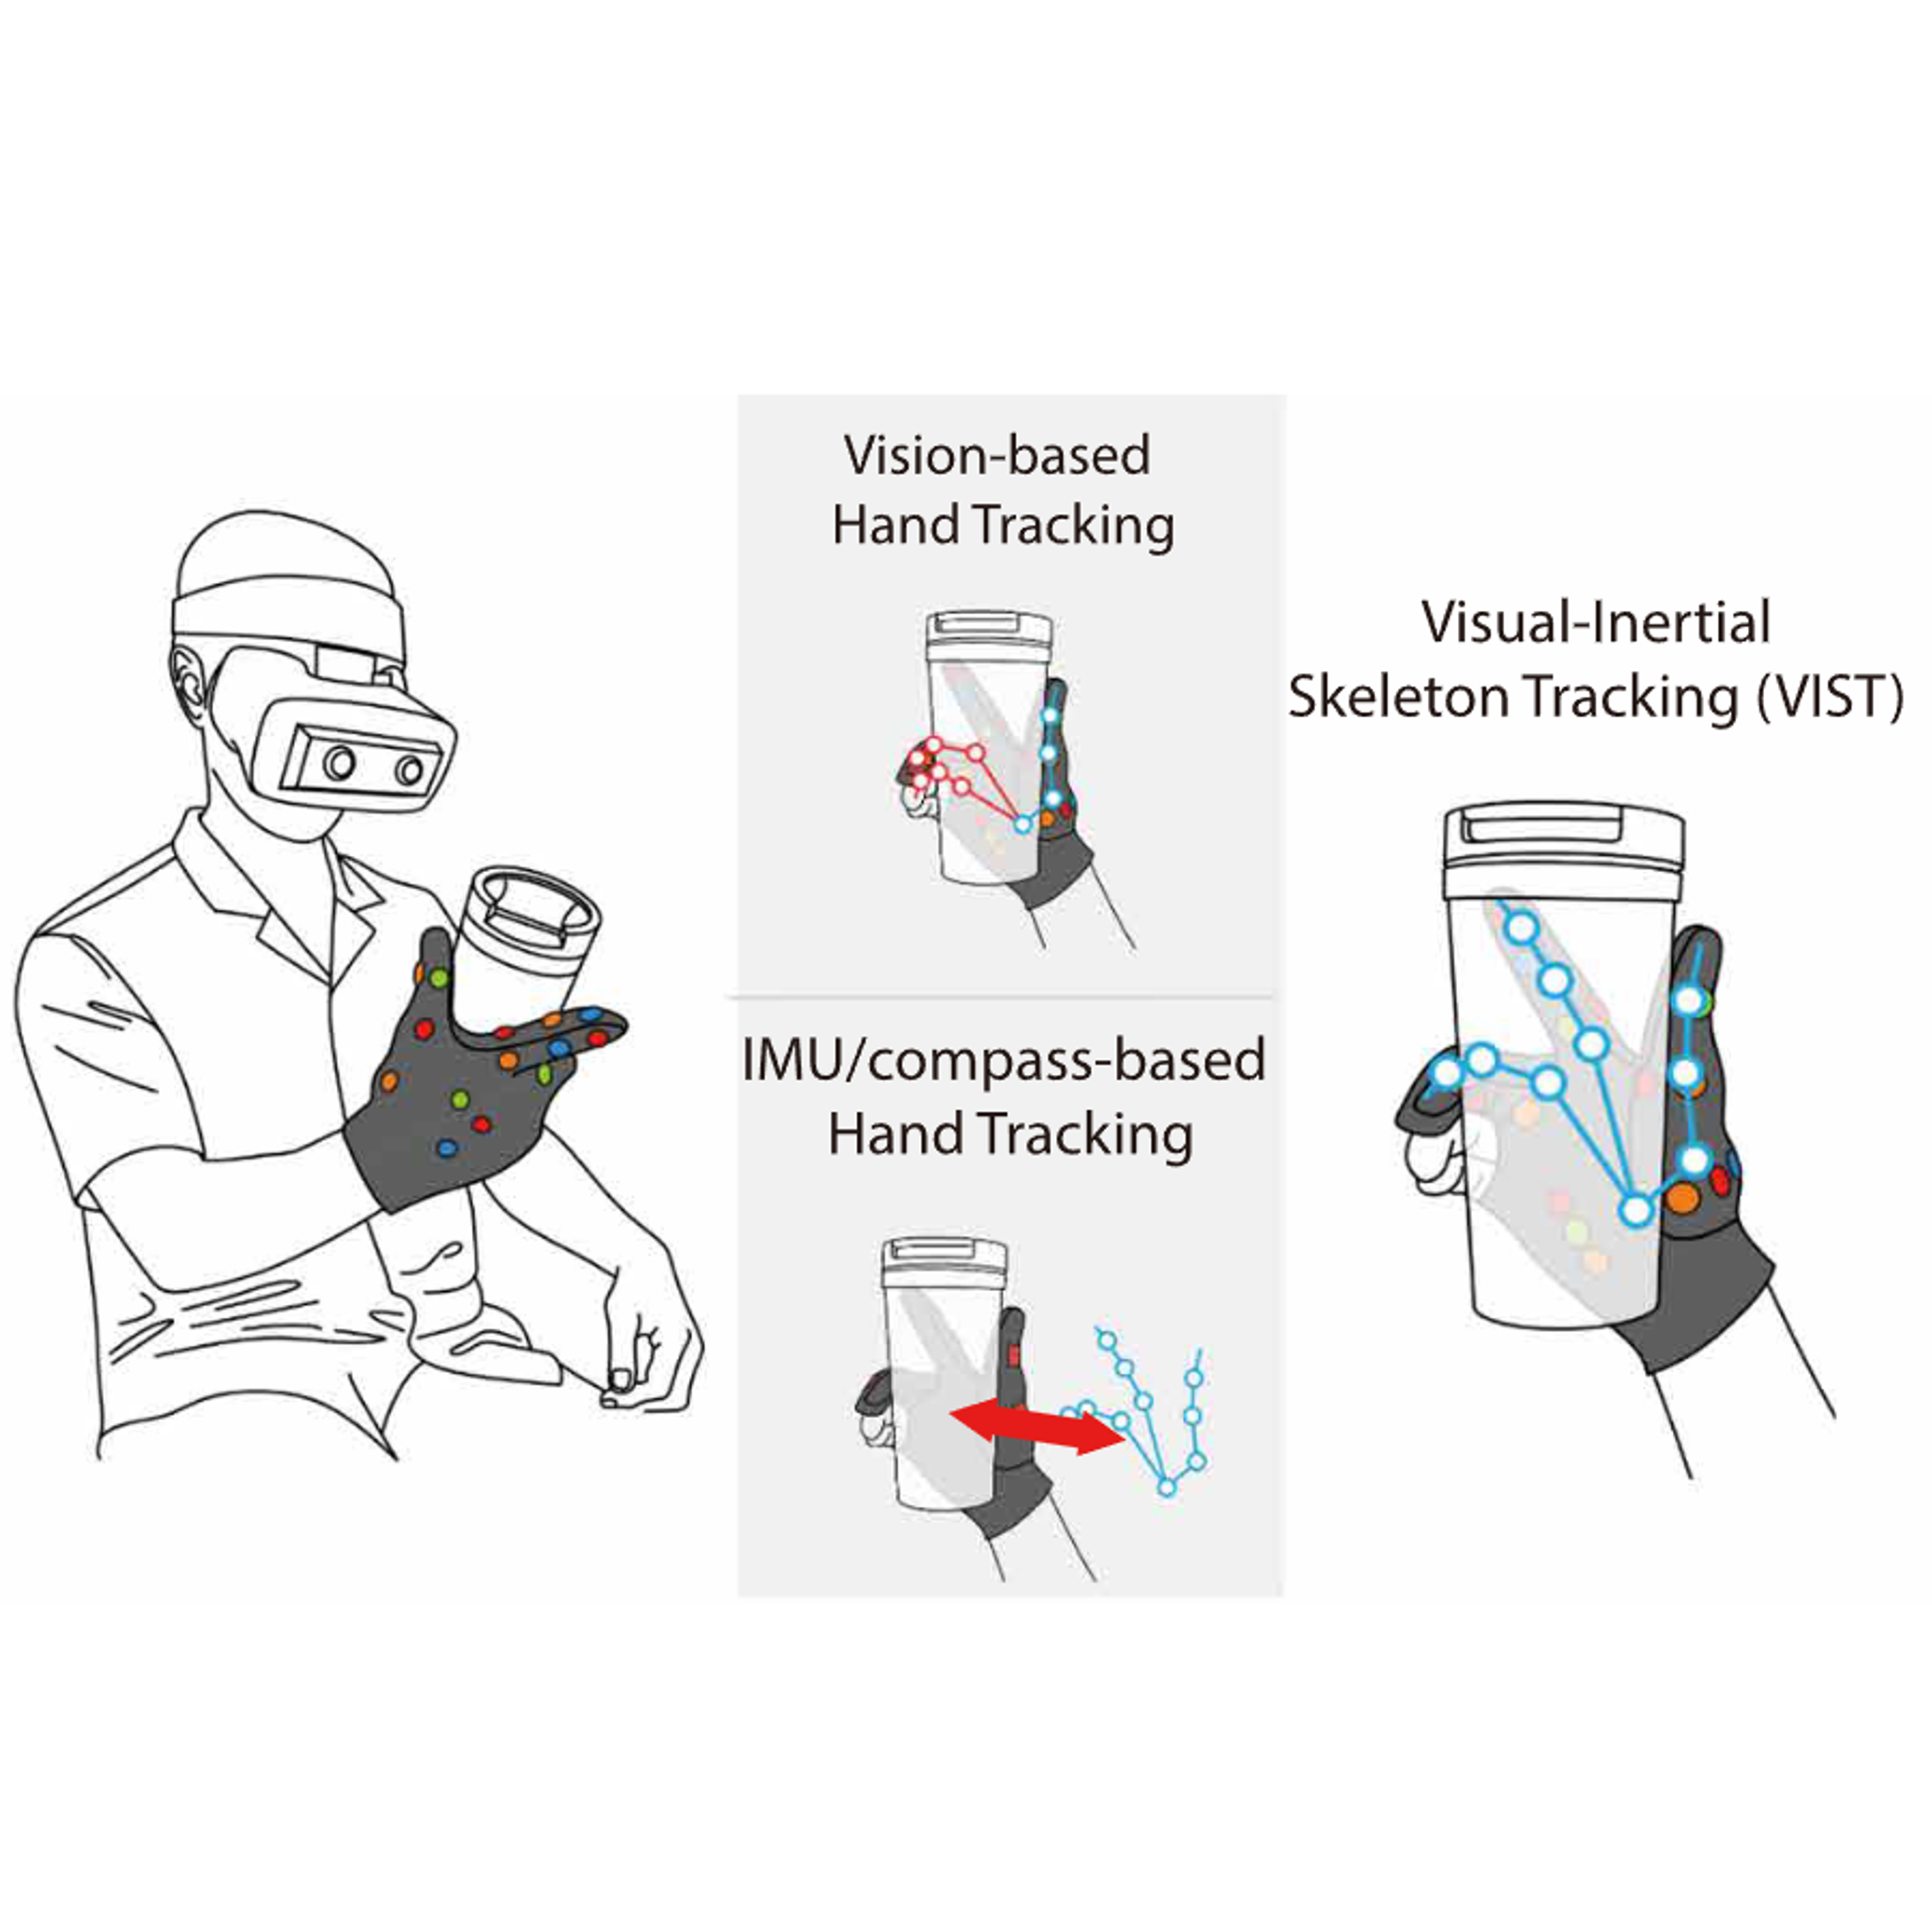
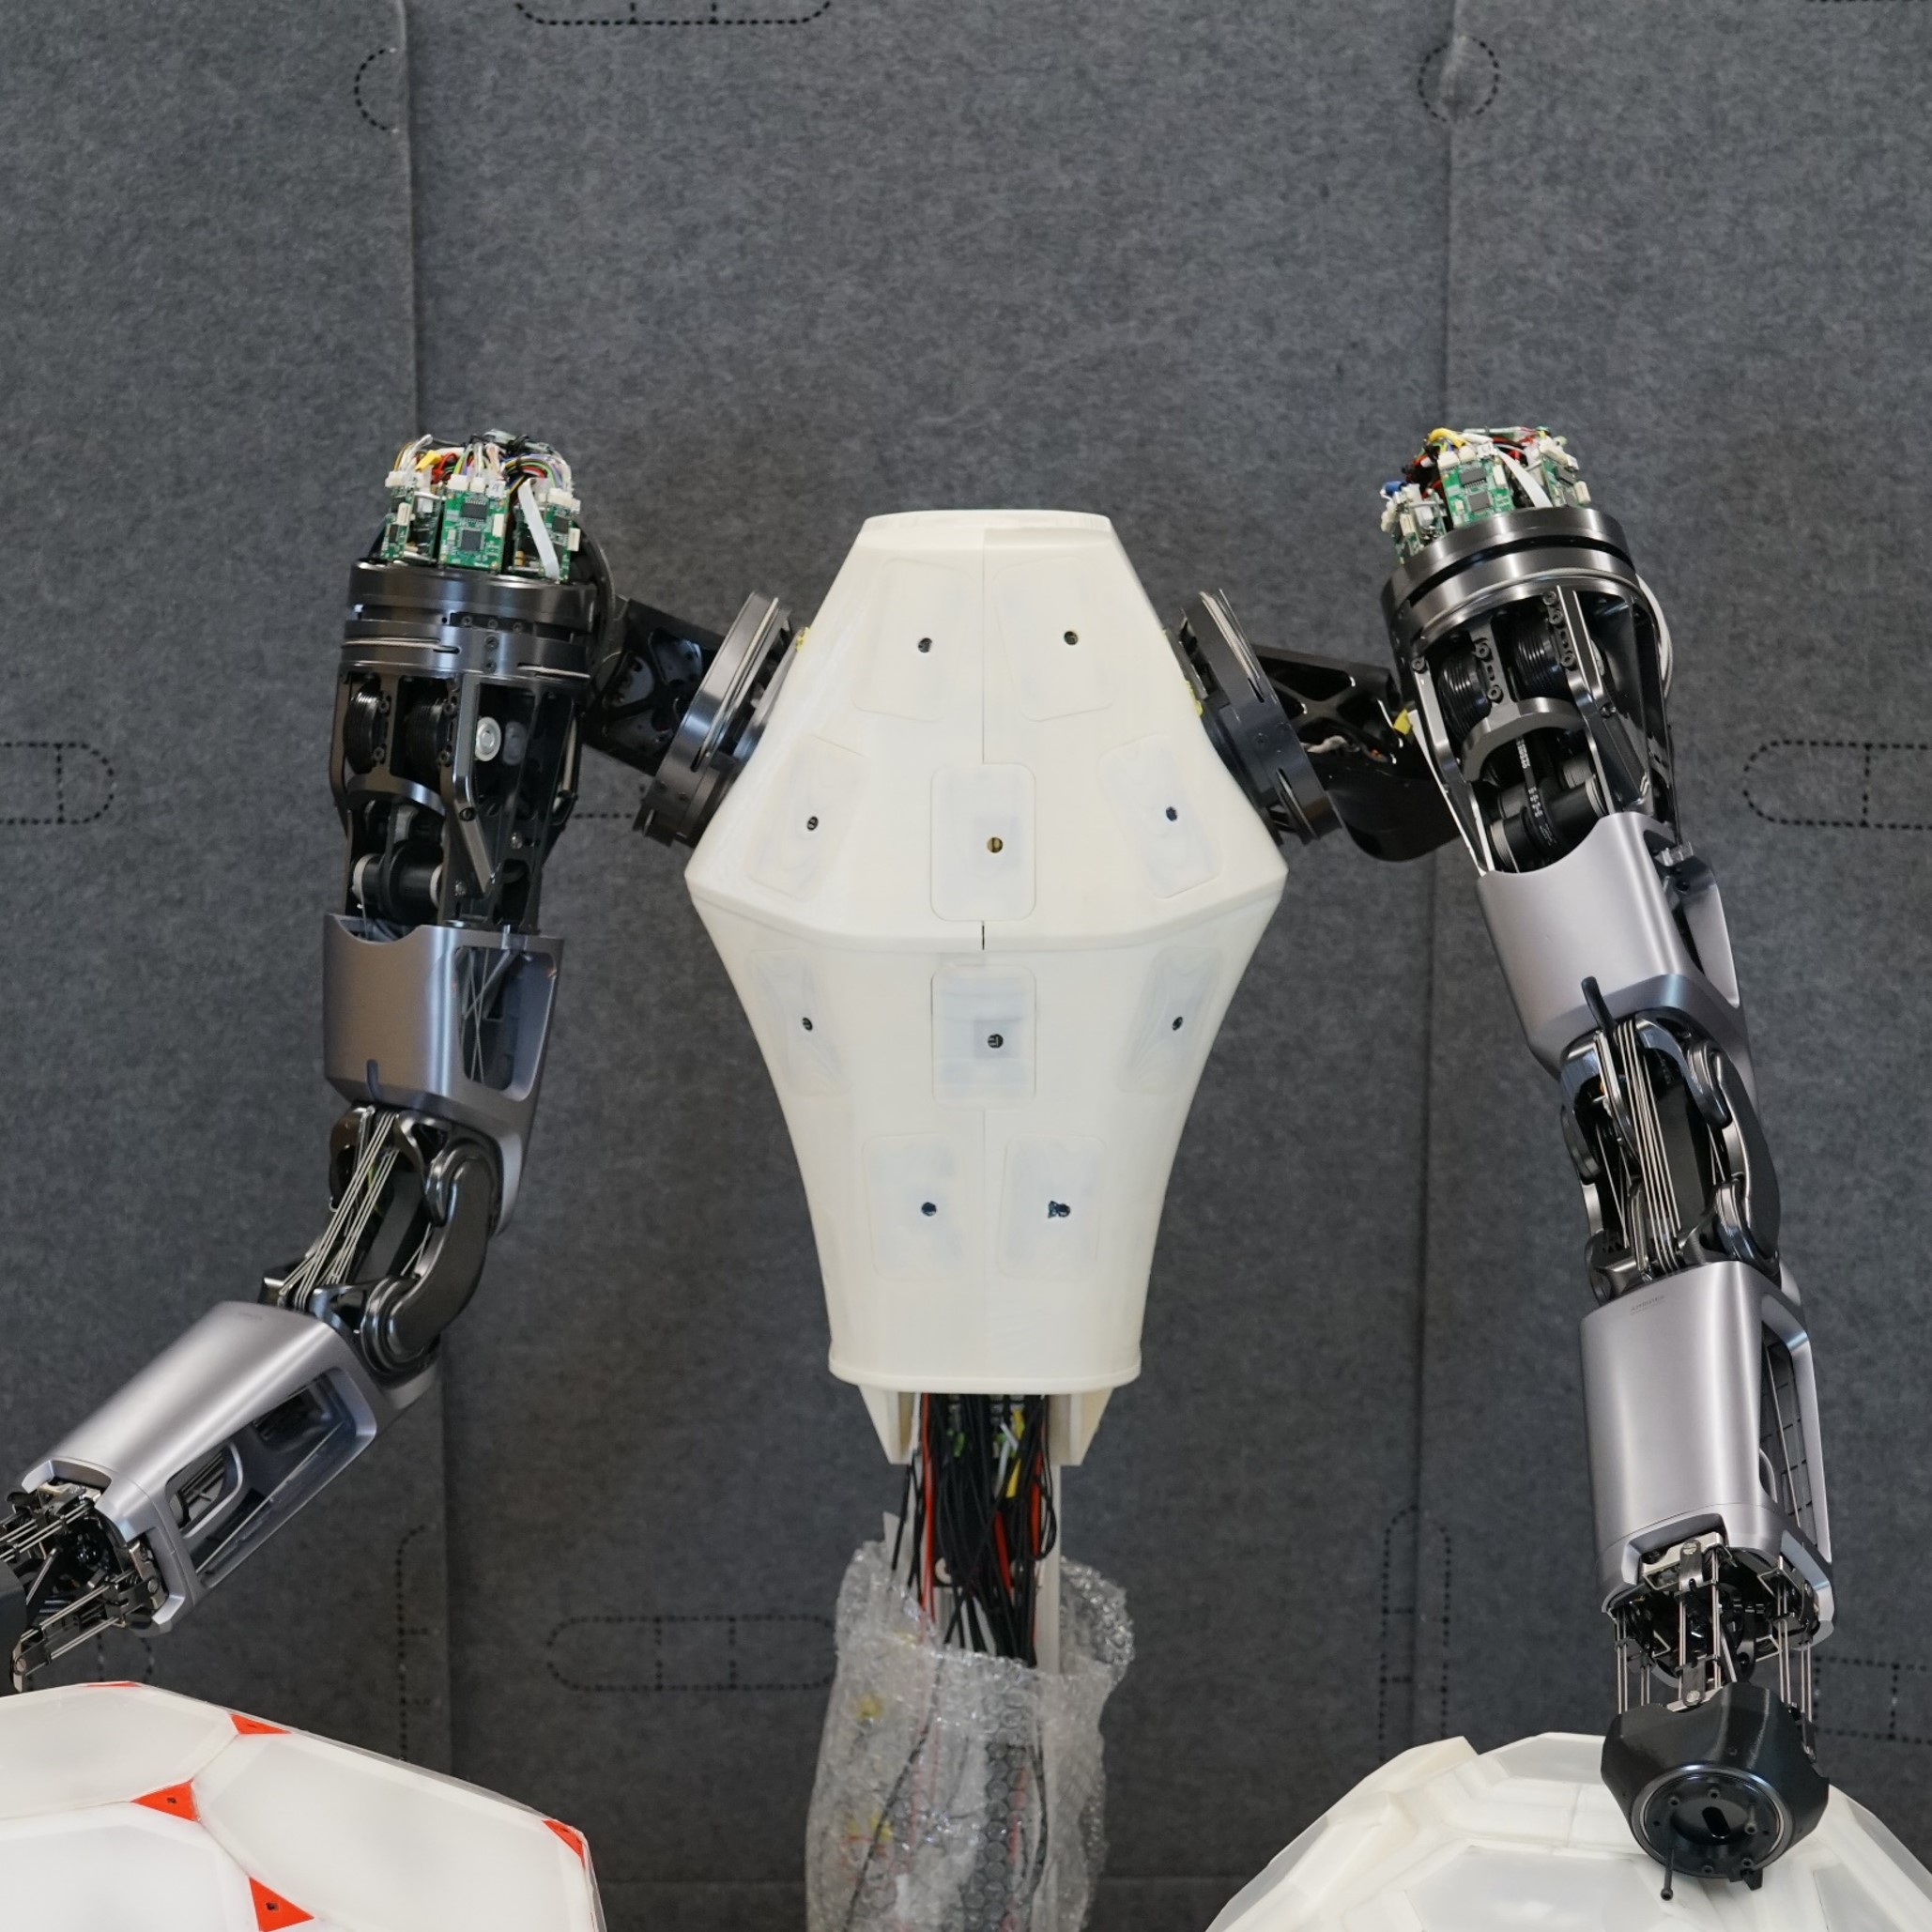
Visual-inertial hand motion tracking with robustness against occlusion, interference, and contact
Yongseok Lee, Won Kyung Do, Hanbyeol Yoon, Jinuk Heo, WonHa Lee, Dongjun Lee Science Robotics, 2021 DOI / Featured in : Seoul National University Press and ETNews Integrates sensor gloves and stereo cameras with a fusion algorithm for precise and reliable hand tracking, improving performance in real-world applications despite challenges like occlusions and electromagnetic interference. |
|
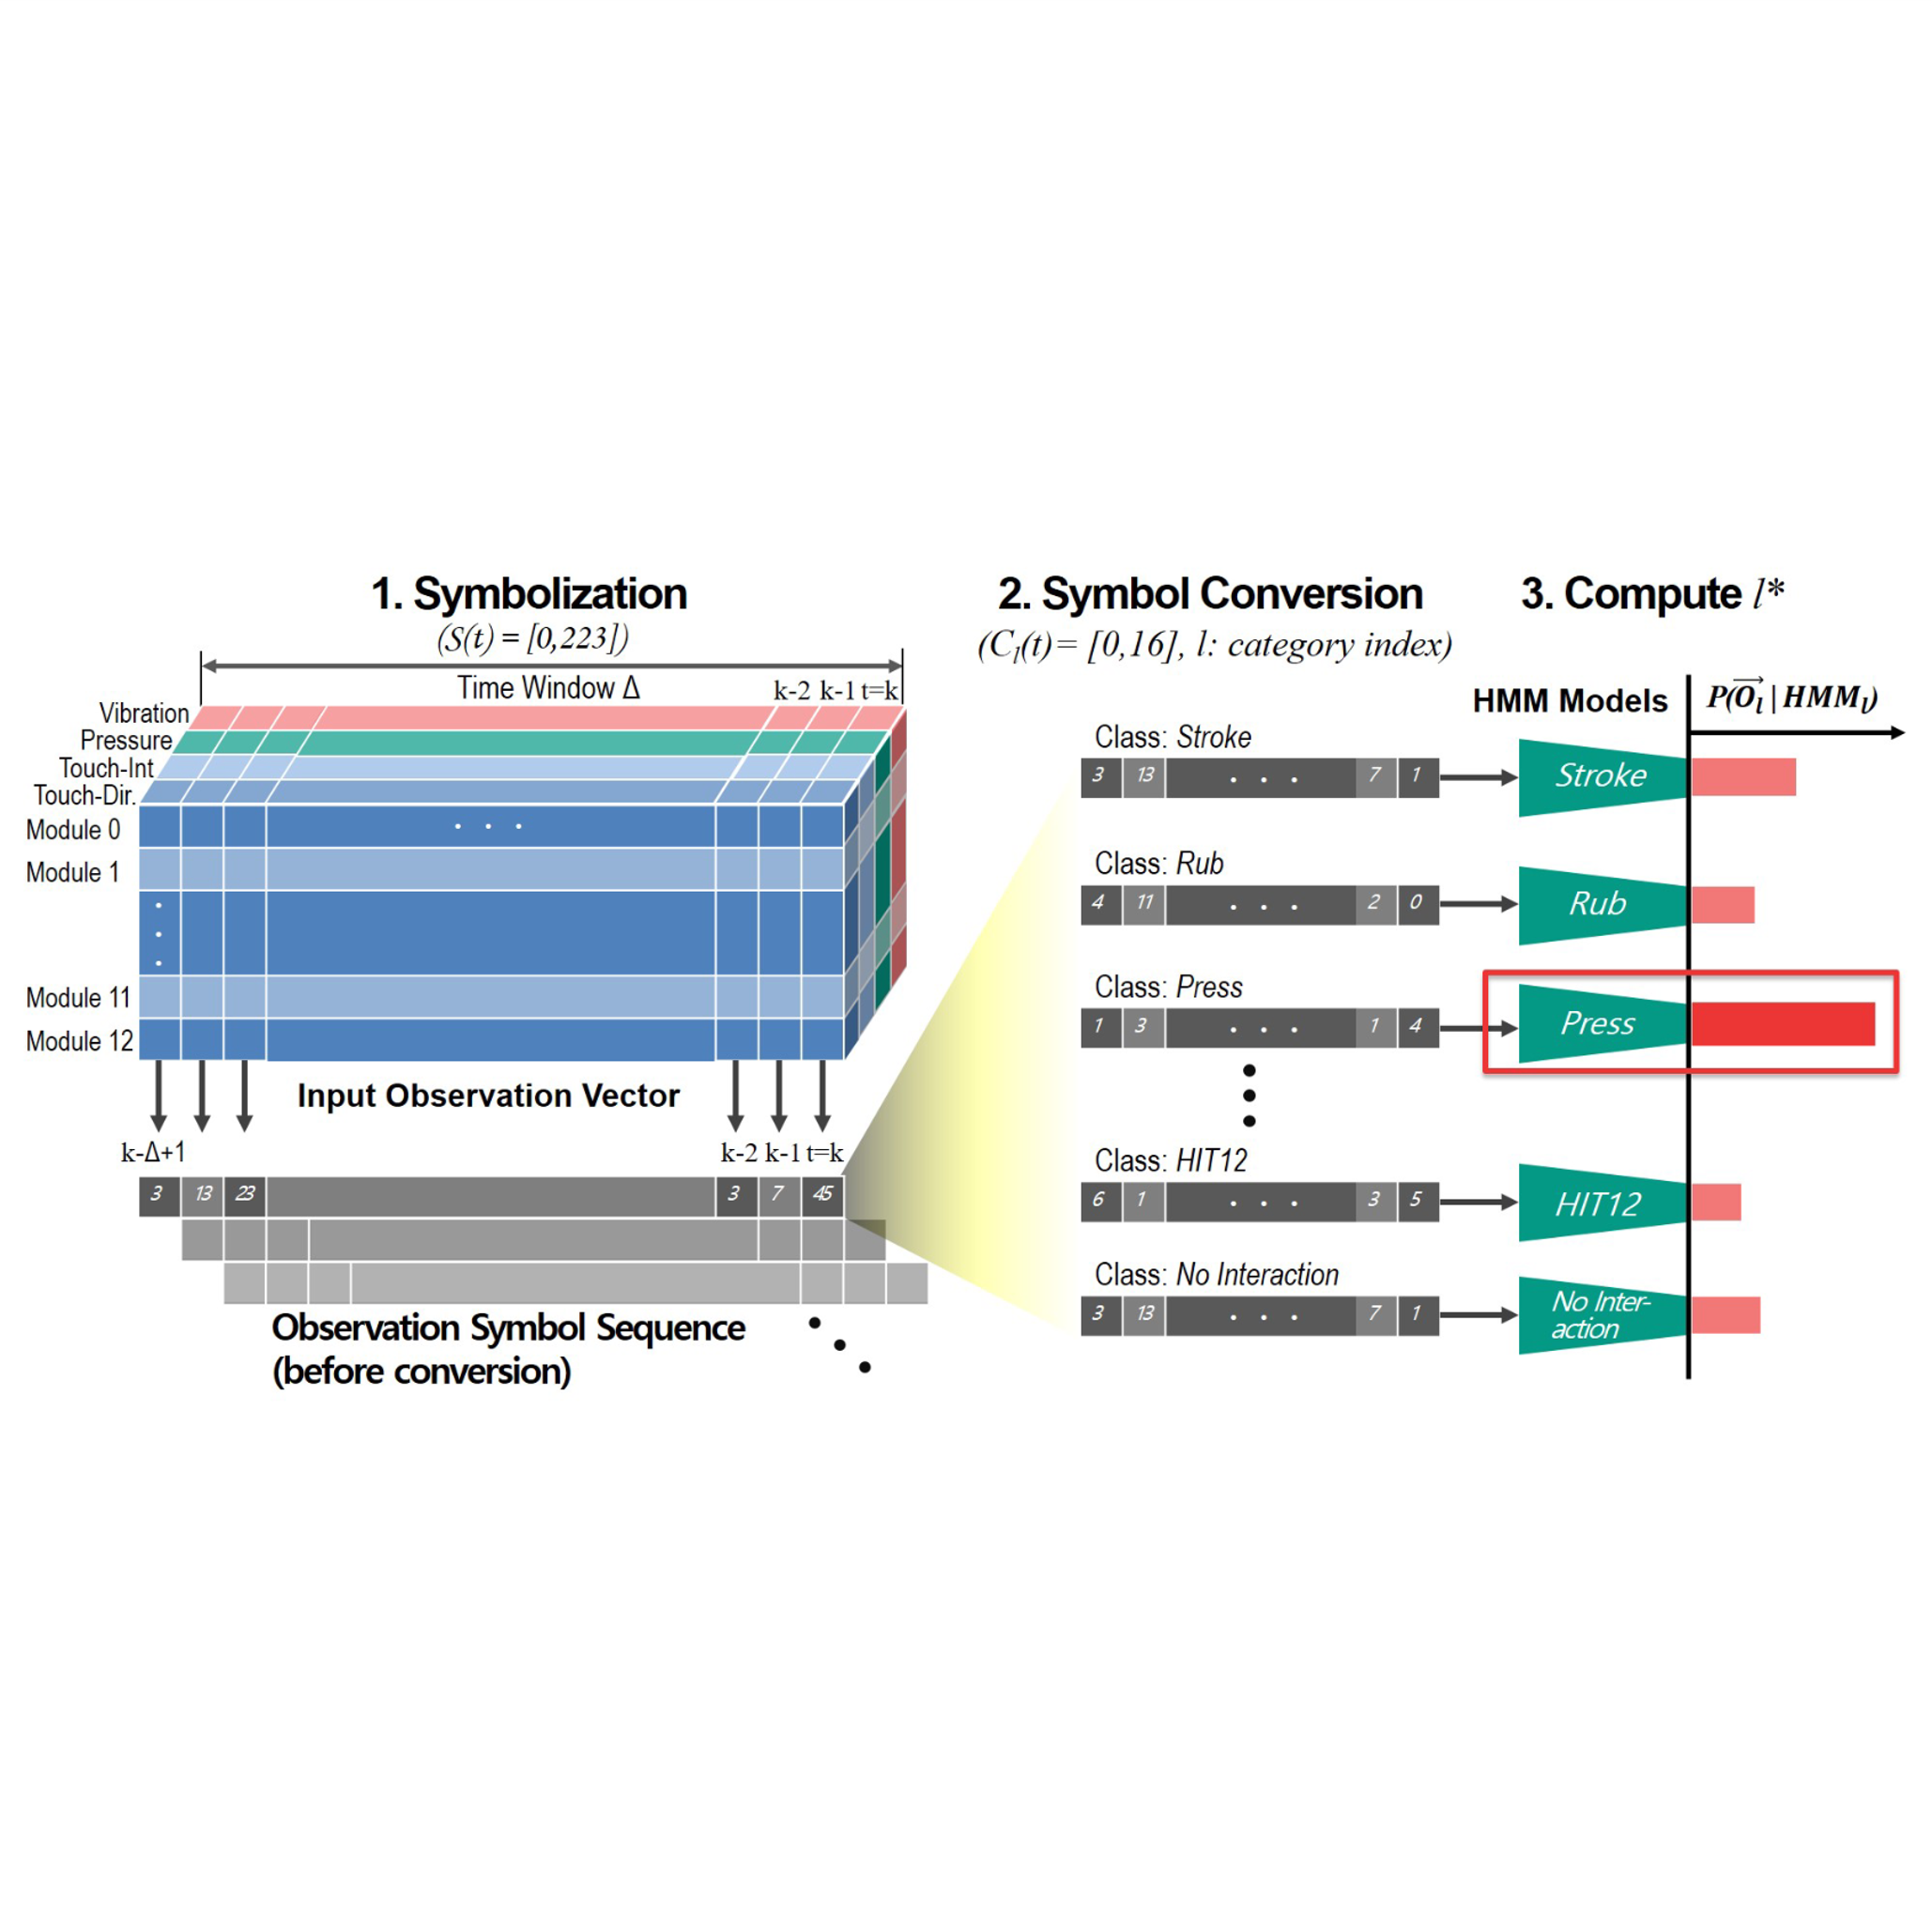
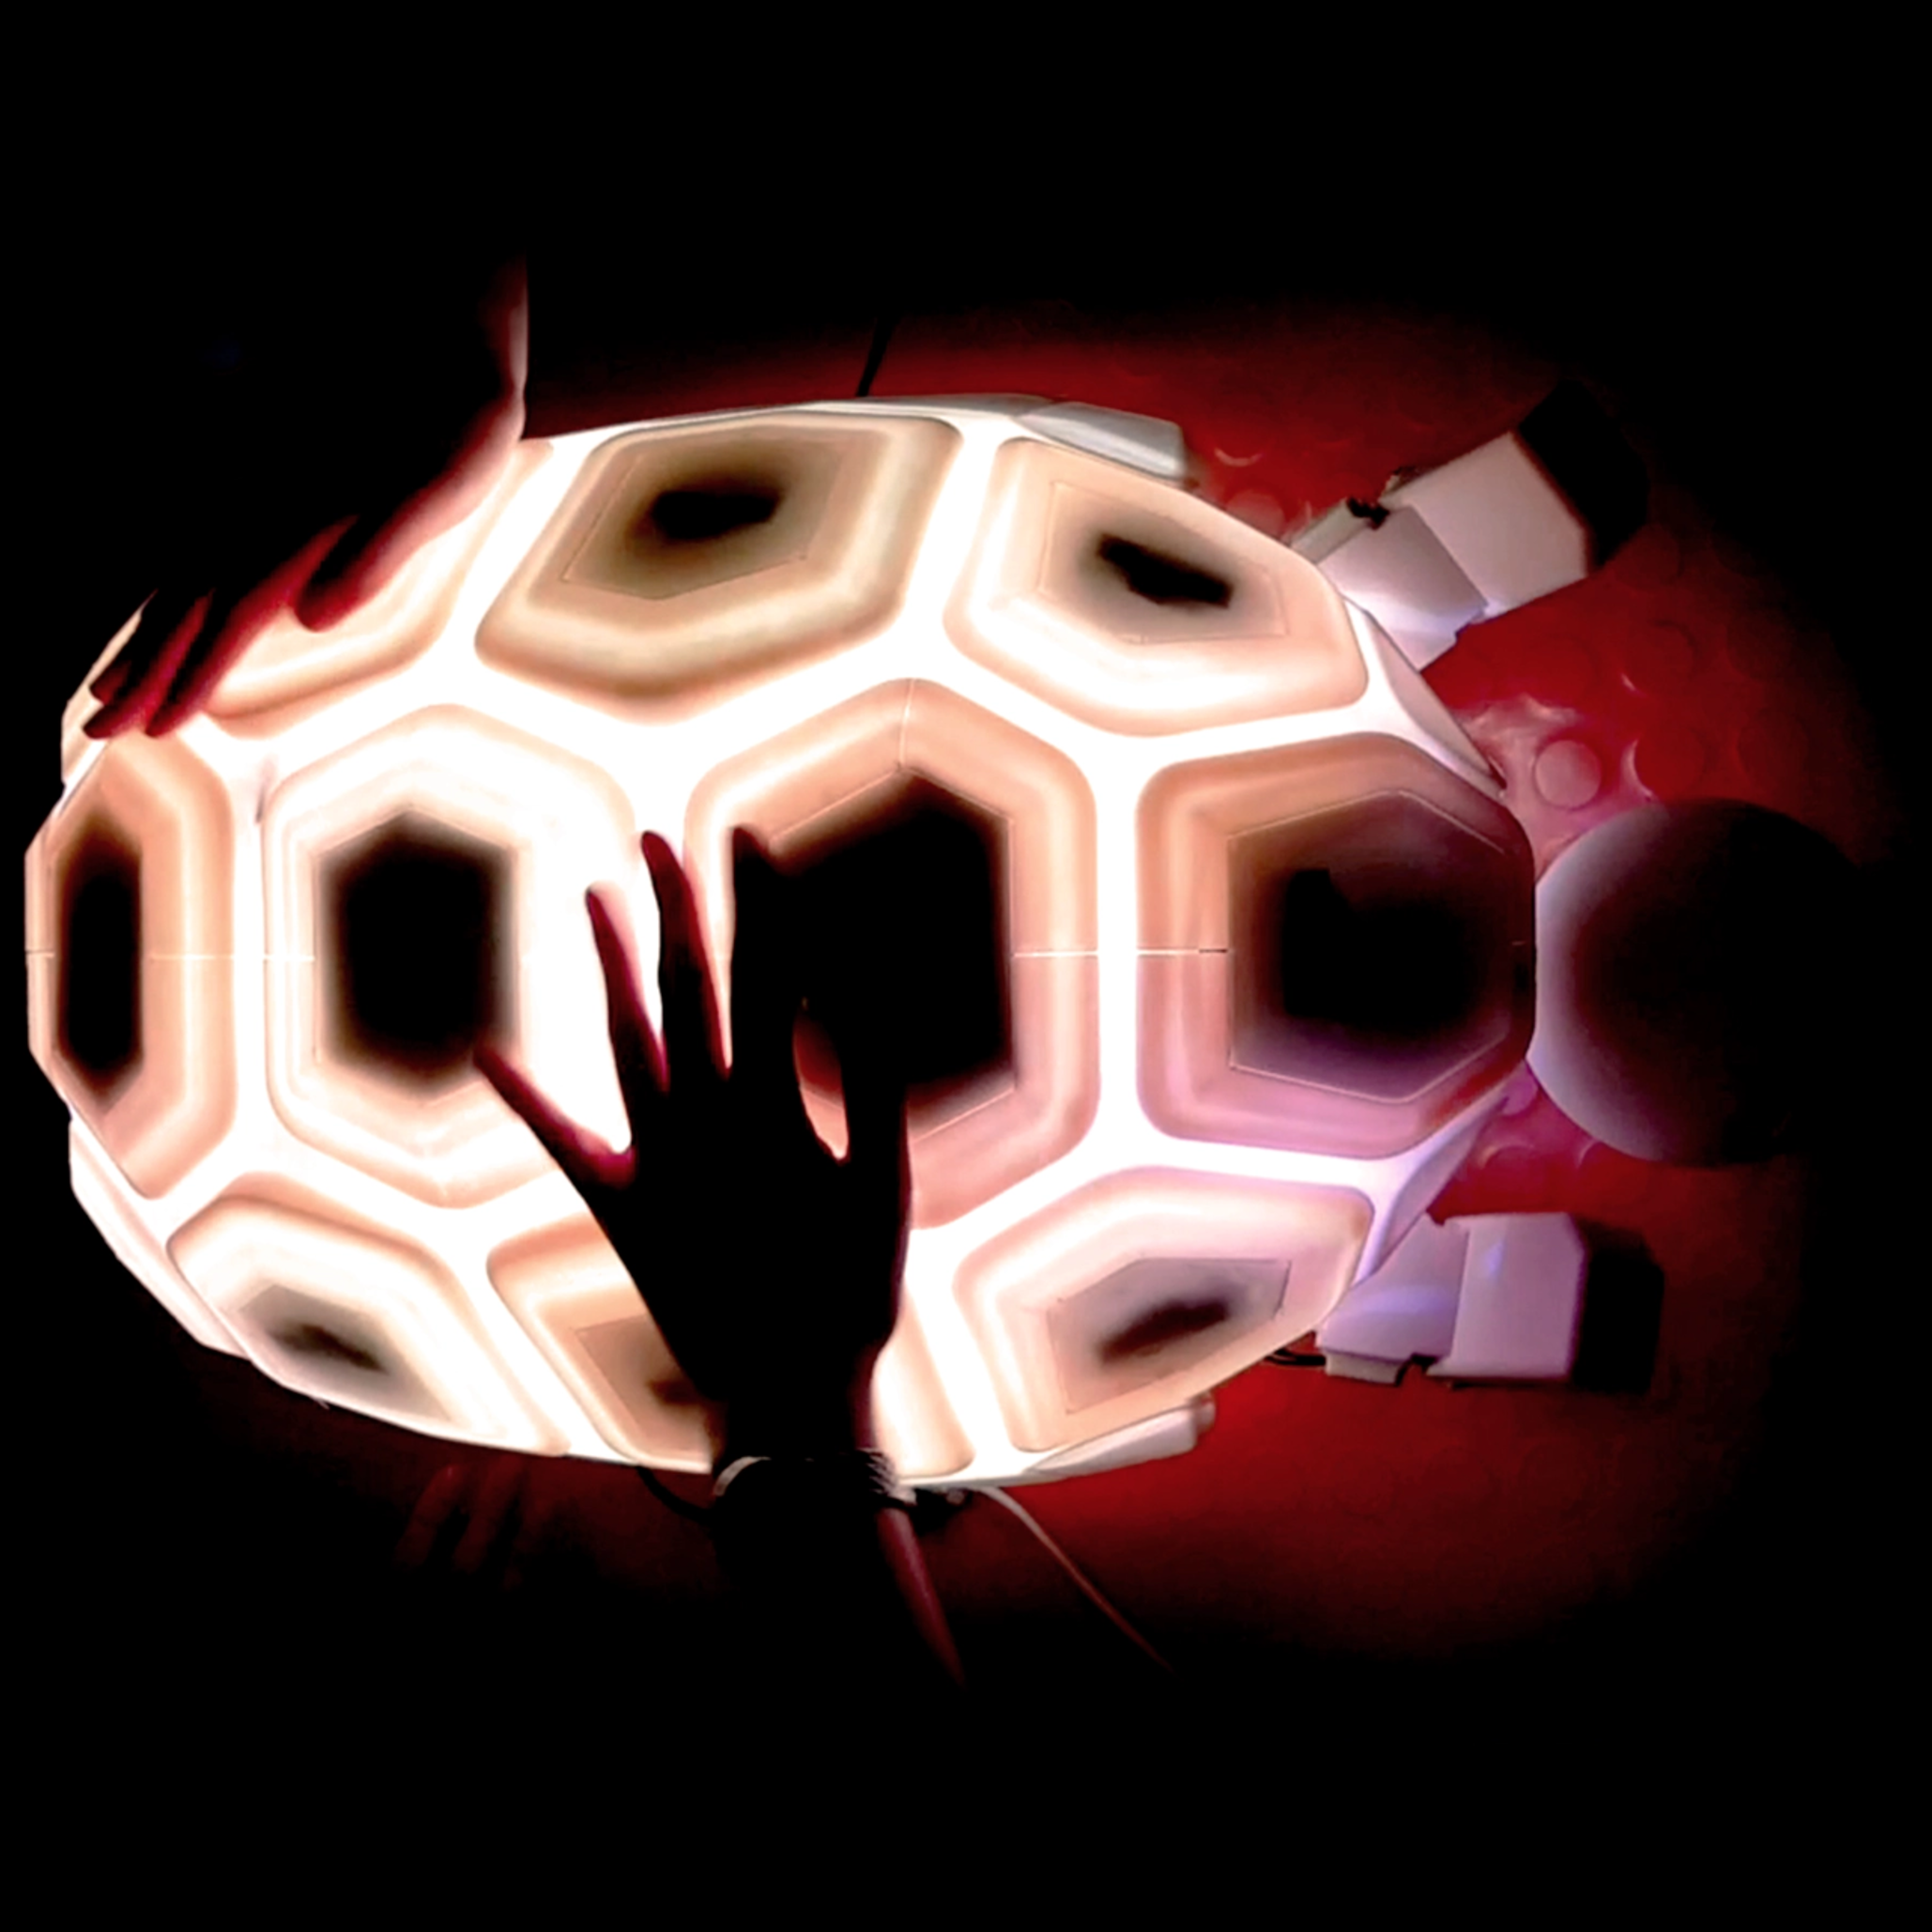
Online social touch pattern recognition with multi-modal-sensing modular tactile interface
HyunJin Ku*, Jason J. Choi*, Sunho Jang*, Won Kyung Do*, Soomin Lee, Sangok Seok UR (International Conference on Ubiquitous Robots), 2019 DOI Introduces a framework combining multi-modal tactile sensing and modular design with a classifier for recognizing social touch patterns, achieving up to 88.86% accuracy using methods like HMM, LSTM, and 3D-CNN. |
 |
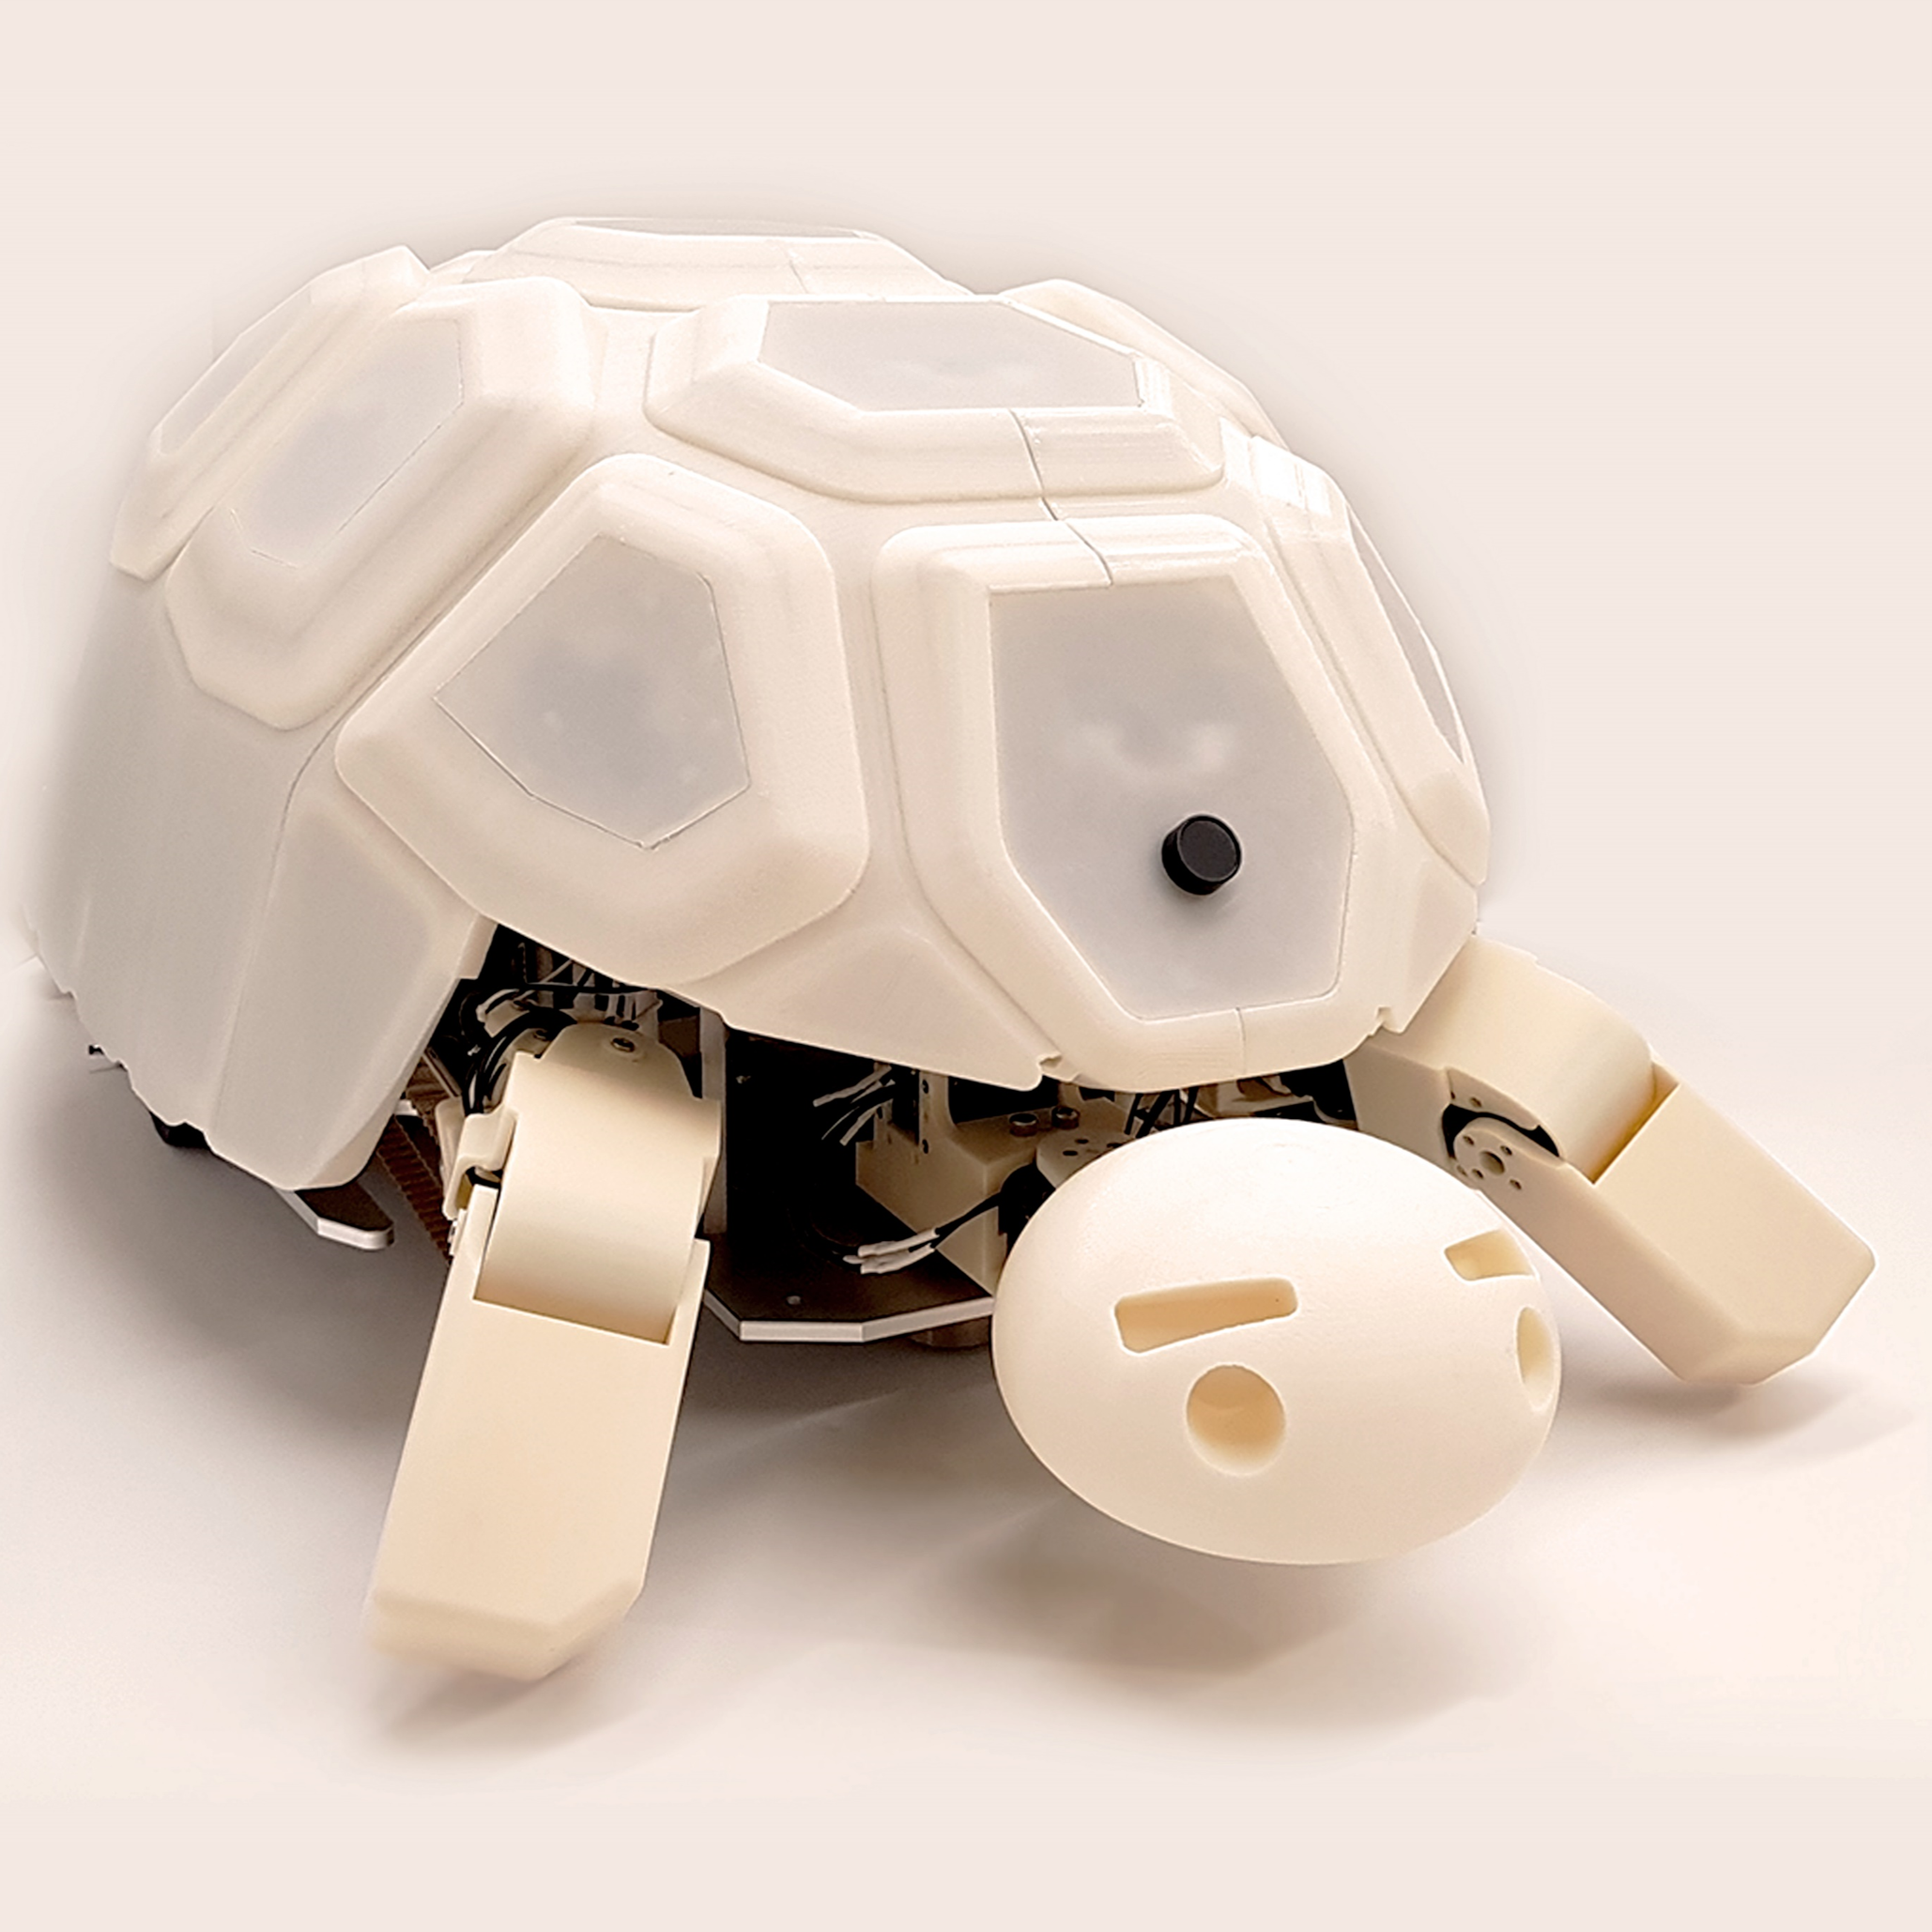
Designing shelly, a robot capable of assessing and restraining children's robot abusing behaviors
HyunJin Ku*, Jason J. Choi*, Soomin Lee*, Sunho Jang*, Won Kyung Do* HRI (Late Breaking Report), 2018 DOI Showed that the robot Shelly effectively reduces children's robot abusing while maintaining their engagement with the robot. |
 |
Shelly, a tortoise-like robot for one-to-many interaction with children
HyunJin Ku*, Jason J. Choi*, Soomin Lee*, Sunho Jang*, Won Kyung Do* HRI (Student Design Competition), 2018 (1st Prize on Student Design Competition) DOI / Video Featured in : IEEE Spectrum, TechCrunch, NBC News-Mach, Fast Company-Co.Design, Seoul National University Press, and HRI Designed "Shelly", a tortoise-like robot that engages with children while mitigating abusive behaviors towards robots. |
Ph.D. Dissertation
Improving Robotic Dexterity with Optical Tactile Sensor DenseTact
|
Patents
Optical Tactile Sensor
|
Service |
|
Reviewer for
IEEE T-RO,
IEEE RA-L,
CoRL,
RSS,
ICRA,
IROS,
CASE, and
Sensors
|
|
Template taken from here. |